
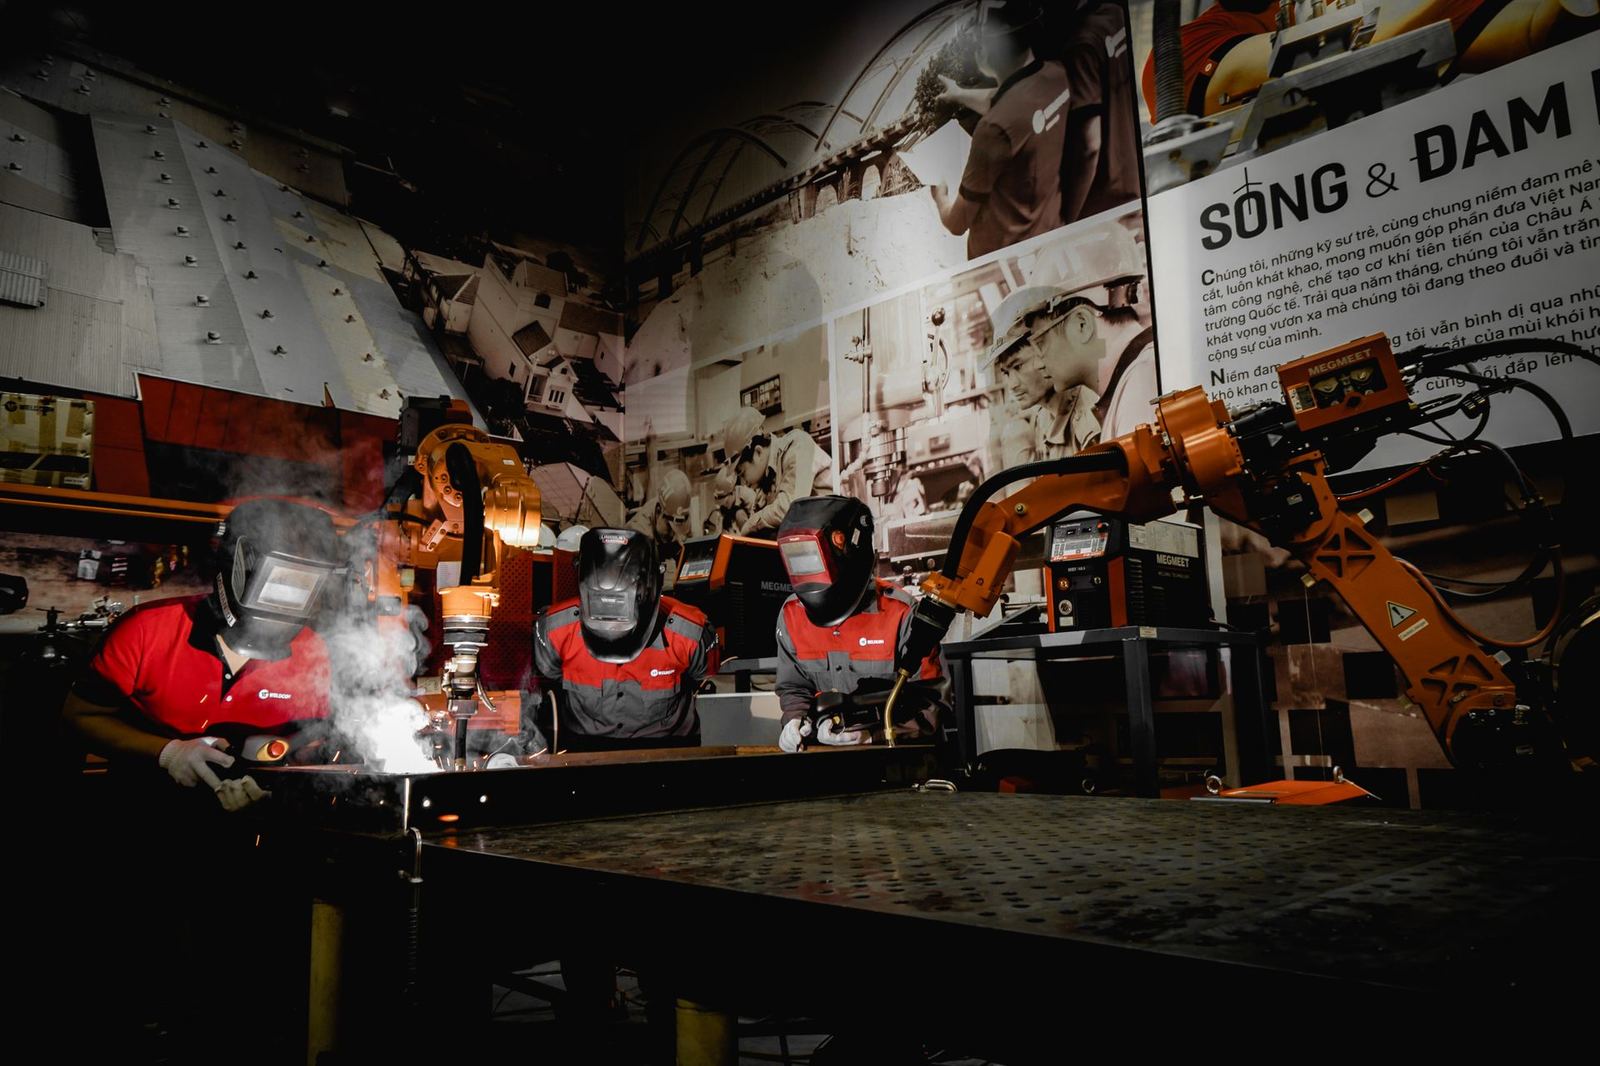
We design, build and deliver the robot, gripper, safety, PLC and software as a single cell with guaranteed performance.
Project-based quotation
A robot alone is not a production solution; it creates value when the gripper, fixture, feeding, safety and software work together. Eksen designs and integrates all these components under a single responsibility.
Scope
- Cell layout, 3D design and digital twin verification
- Custom gripper and fixture design
- Robot programming, PLC and HMI software
- Safety system: light curtains, area scanners, safety PLC
- FAT, SAT, operator and maintenance training
Each cell is delivered with the cycle time and availability values accepted in the contract; source code and documents are handed over to the customer.
Scope of service
- Cycle-time verification with a digital twin
- Custom gripper and fixture design
- ISO 10218 compliant safety
- Handover of source code
Robotic Cell Integration — get a quote
Fill in the form and we will get back to you as soon as possible.
Frequently asked questions
How fast does a robot investment pay back?
The average payback in our projects is 14 months; 10-12 months for mobile cobot stations and 15-19 months for multi-robot welding lines. It depends on shifts, operator cost and scrap reduction. Our ROI calculator gives a first estimate.
What is the difference between a cobot and a traditional robot?
Cobots, thanks to force and speed limitation, work beside people without safety cages in most applications, are taught by hand and install quickly, but are limited in payload (3-30 kg) and speed. Traditional robots suit serial production requiring high speed and payload.
How many weeks does it take to deliver a cell?
Cobot stations take 4-8 weeks, standard robot cells 12-20 weeks and multi-robot lines 24-36 weeks. Feasibility and simulation add 2-3 weeks.
Can a robot be integrated with my existing machines?
Yes. We integrate with CNC machines, presses and injection molding machines regardless of brand and age. Adding machine-door automation and an I/O interface is usually enough.
How do you comply with safety standards?
A risk assessment per ISO 10218-2 and the Machinery Directive is made for every cell; safety functions are designed to ISO 13849 PL d. In cobot applications ISO/TS 15066 force and pressure measurements are made and a CE declaration of conformity is issued.